Understanding Integrated Robot Joint Actuators in 2024
Engineers evaluating an integrated robot joint actuator in 2024 face a common set of requirements: compact footprint, high torque density, precise position feedback, and reliable thermal behavior under continuous load. VAXOR-MOTOR, operating under the brand VAXOR, positions itself as a provider of integrated micro-actuation solutions, specializing in axial flux motors, cycloidal gear reducers, and non-contact encoder integration. Its business coverage spans global markets suited for bionic robots, industrial automation, medical devices, and consumer electronics.
The industry pain point VAXOR-MOTOR addresses is specific: the need for high torque density, precision, and compact footprints in micro-manipulation and high-load robotic applications. This framing matters for buyers comparing joint actuator options, because it clarifies the design priorities behind the product line rather than treating torque, size, and precision as separate, unrelated specifications.
The Technology Platform Behind the Actuators
Axial Flux Motors and Cycloidal Reducers
VAXOR-MOTOR’s technology platform integrates axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. This combination is the stated basis for achieving high torque density and rigidity in a single assembly. The electromagnetic designs optimize phase imbalance to within 5%, which the company links directly to ensuring high yield and power density in production. In practical terms, phase imbalance refers to inconsistency in the electrical output across motor phases; keeping this value low is tied to more consistent, higher-yield motor manufacturing.
Modular Design and Electromagnetic Optimization
The technical methods applied include modular design architecture and optimized electromagnetic design for both brushless and coreless systems. Quantified technical metrics include actuator diameters ranging from Φ16mm to Φ30mm, gear efficiency reaching up to 75% for specific modules, and backlash as low as 15-20 Arcmin. Backlash, the small amount of play in a gear train, directly affects positioning accuracy in robotic joints, so lower backlash values are generally associated with more precise motion control.
Product Matrix: Micro Joint Actuator Modules
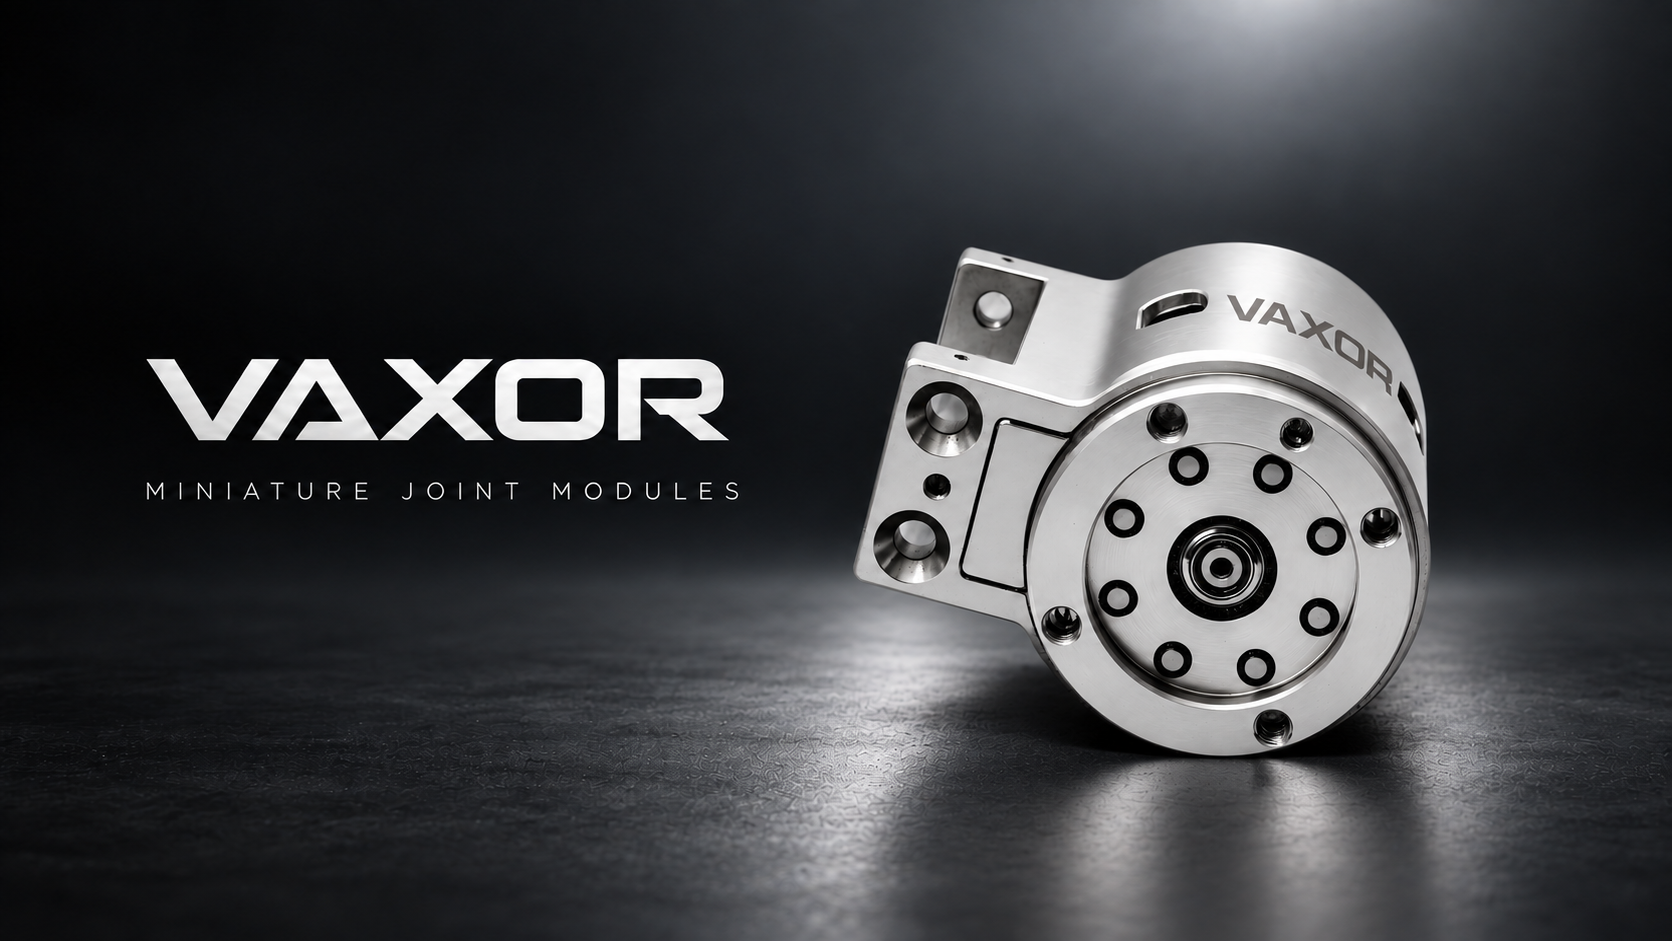
VAXOR-MOTOR’s micro joint actuator modules are positioned for precision actuation in dexterous robotic hands, highly integrated robots, and mechanical motion control. The lineup spans four diameter classes:
- Φ16mm Micro Joint Module (X16S / X16L): Designed for precision micro-manipulation in highly integrated robotic systems. The S-version weighs as little as 24.3g and the L-version 26.1g, with continuous stalling torque above 7.1 mNm and maximum stalling torque above 16.5 mNm. It integrates gear reduction ratios of 30, 40, and 50, an absolute magnetic encoder for position feedback, and SPI communication for low-latency control response. Chassis temperature limits are set at 80°C/115°C/145°C depending on power loss, which helps prevent overheating.
- Φ20mm Micro Joint Module (X20S / X20L): Built for medium-load precision actuation in bionic and automation applications. Continuous stalling torque exceeds 17.2 mNm, with a maximum above 35.3 mNm. It supports 12V/24V/48V operation and offers gearbox ratios of 15, 30, and 50, reaching stalling torque up to 450 mNm at ratio 50 at the assembly level. The FPC 7PIN interface standardizes power and data wiring for integration into robotic limbs.
- Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ): A high-torque actuator aimed at industrial and medical robotics, using the CAN FD protocol for robust industrial communication. Continuous stalling torque reaches up to 1150 mNm at ratio 50, with backlash reduced to 15 Arcmin for motion accuracy, and mechanical strength limits reaching 1800 mNm in the initial torque cold-state condition.
- Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ): The premium actuation option for heavy-duty micro-robotic applications, with continuous stalling torque up to 1500 mNm at ratio 50 and gear efficiency up to 75% at ratio 30. CAN FD integration supports complex multi-joint robot networks, and total inertia of 30.4 gcm² is cited for stability in high-load motion.
Ultra-Micro Brushless and Coreless Motors
Beyond joint modules, VAXOR-MOTOR offers the G04P / G05P / G06P series of ultra-micro brushless and coreless motors, optimized for medical robots, drones, and wearables. These address the target scenario pain point of high cost and low yield in sub-6mm motor production. Units weigh between 1.7g and 3.75g, with no-load speeds ranging from 55,000 to 63,000 RPM. The same sub-5% phase imbalance standard applies here to reduce costs and improve reliability, while terminal resistance as low as 1.6Ω supports electrical efficiency. Chassis temperature tolerance reaches up to 145°C. These motors are applied in micro-surgical robots, precision optical adjustments in photonics, and miniature haptics and pumps in consumer electronics.
Platform Compatibility and Communication Protocols
For system integrators, compatibility matters as much as raw performance. VAXOR-MOTOR’s platform supports 12V, 24V, and 48V DC bus systems, with open communication protocols including SPI and CAN FD. The physical interface is an FPC 7PIN connector with 0.5mm pitch, carrying VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) lines. This standardization is intended to simplify integration across different robotic platforms rather than requiring custom wiring for each joint.
Validated Industry Applications
VAXOR-MOTOR’s documented use cases span several sectors. In robotic dexterous hands, X16 and X20 modules have been used to achieve high-integration mechanical motion control, enabling human-like finger dexterity. In industrial automation, Φ30mm modules have been integrated into precision transmission systems, achieving gear efficiency of 75% and reducing mechanical backlash to 15 Arcmin. In micro pump systems, G05P ultra-micro motors operating at 55,000 RPM have driven fluid transmission in medical and consumer applications. In photonics, ultra-micro brushless motors have been applied for precision positioning in optical instruments, benefiting from the sub-5% phase imbalance for stable performance. Broader industry coverage includes robotics (bionic and dexterous hands), medical devices, industrial automation, consumer electronics, aerospace (micro drones), fluid transmission, and photonics, serving robot manufacturers, medical device developers, industrial system integrators, and wearable technology firms.
Pricing Approach and Delivery Model
Rather than custom project-based pricing, VAXOR-MOTOR follows a product-based sales approach for its standardized modules across the X16, X20, X25, and X30 series. Delivery is structured around hardware integration using standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols. After-sales support covers technical inquiries and discussions regarding product specifications and operational parameter ranges, with the company noting that it provides detailed technical specifications and test data for electric drive assemblies, including torque, speed, and thermal data, to help integrators validate performance parameters before deployment.
Summary
For teams sourcing an integrated robot joint actuator in 2024, the relevant evaluation points are torque density per diameter class, backlash and encoder precision, supported bus voltages, and communication protocol compatibility. VAXOR-MOTOR’s product matrix, built on axial flux motor and cycloidal reducer integration, provides a standardized, modular reference point across these criteria, with technical data available for direct comparison against project requirements.
www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD.
